Dual Loop Cascaded Position Control
Overview
Using a gear can cause inaccuracy when only the shaft is controlled. For optimized position control, a second encoder can be attached to the output shaft after the gear.
This section explains how the cascaded position controller can be configured for a dual encoder setup.
General view (click to enlarge)
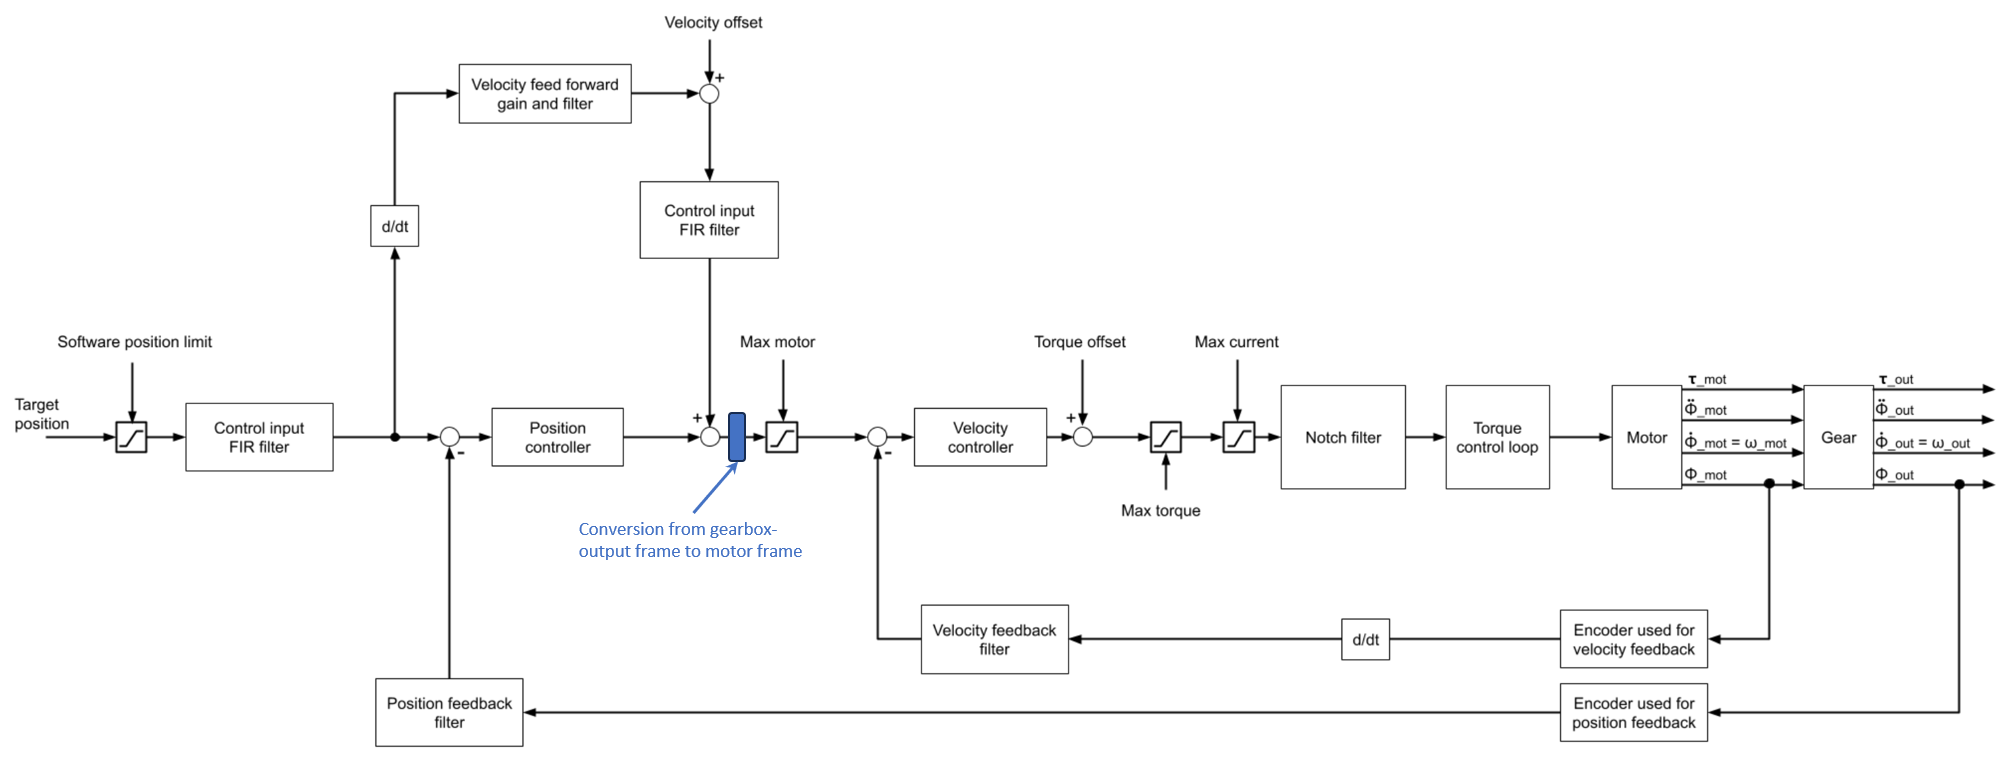
Detailed view (click to enlarge)

Note: The specified units of the PDOs are only valid for the default unit configuration.
If user defined velocity (e.g., mRPM, rad/s) or position units is configured, they will be used instead. Additionally, in this particular configuration, the following Objects: 0x606C Velocity actual value, 0x60B1 Velocity offset, and 0x606B Velocity demand value are defined in the gearbox output reference frame, not in the motor frame.
For additional information, see Velocity feed forward under Motion Control / Extended Control Functionalities.
Attention: The Control input FIR filter is not applied to the Feedforward Velocity in versions older than v5.0.4.
Usage
-
Set the first encoder at the input shaft to Commutation and Velocity.
-
Set the second encoder at the output shaft to Position.
-
Ensure that the gear ratio is set correctly in Object 0x6091.
Parameters
| Object ID | Name | Description |
|---|---|---|
| 0x6091 | Gear Ratio | Defines the ratio of motor shaft revolutions to driving shaft revolutions |
| 0x2010 | Torque Controller | Values Kp, Ki and Kd for Torque Controller |
| 0x2012 | Position Controller | Values Kp, Ki and Kd for Cascaded Position Controller (Both loops: Position and Velocity) |